Technical foundation
My first technical role was at Auto-Chlor, servicing, installing, diagnosing, and refurbishing commercial dishwashing equipment across mechanical, electrical, plumbing, and chemical systems.
Hardware prototype engineering
I build the harnesses, fixtures, debug tools, and embedded systems that make prototype hardware real for robotics, autonomous vehicles, and fast-moving R&D teams.
I specialize in turning incomplete engineering ideas into physical systems that can be built, tested, debugged, documented, and handed off. My work sits where electrical integration, mechanical fabrication, lab operations, sourcing, and practical troubleshooting meet.
About Me
Repair it. Understand it. Give it a second life. Then build what comes next.
I was born in Brazil and grew up with limited resources, but I was always fascinated by machines, electronics, and robots. Building the things I imagined once felt out of reach. After coming to America, I found the tools and opportunities to reconnect with those early dreams and turn them into real systems.
Much of what I know is self-taught. I learn by taking things apart, studying how they work, experimenting, and troubleshooting until I find a solution. That instinct has carried me from field service into prototype hardware, robotics, and autonomous vehicles.
My first technical role was at Auto-Chlor, servicing, installing, diagnosing, and refurbishing commercial dishwashing equipment across mechanical, electrical, plumbing, and chemical systems.
My home lab is where I repair electronics, build battery packs, experiment with solar energy, fabricate furniture and shelving, install lighting, and develop practical systems for daily life.
I restored several nonworking 3D printers and turned them into useful fabrication tools. I also designed an outdoor PVC misting system to make hot summer days more comfortable.


How I Solve Problems · Case Study 01
Portable CAN debugging without the laptop bottleneck.
When an e-bike or prototype system needs fast network visibility, waiting on a full laptop setup slows everything down. I built a mobile CAN debug tool with live frame capture, configurable baud rates, on-device filtering, TFT visualization, and signal generation for validation work.
From Requirement to Validation
The goal was not simply to read CAN traffic. The tool had to be portable, fast to deploy, easy to operate at the bench, and useful for both diagnosing a system and validating software behavior.
Problem
A laptop, interface, cables, and software configuration created friction before useful data could be captured.
Requirements
Live frames, selectable baud rates, filtering, a readable display, and controlled signal generation became the core requirements.
Engineering
I selected the architecture, assembled the hardware, built the interface, and iterated around real bench usability.
Validation
The prototype was exercised against known network traffic and bench scenarios to confirm repeatable operation.
Outcome
The finished prototype condenses essential CAN diagnostic functions into a portable tool—helping a technician move from connection to useful information without building a full laptop-based test setup.
Featured System


Build Gallery


Experience
Manufacturing Engineer
Supporting prototype development, manufacturing readiness, process improvement, and the transition of complex hardware from engineering designs into reliable, repeatable builds.
Prototype / Hardware Engineering Technician
Released 30+ harnesses and prototype cable assemblies, owned Raspberry Pi integration support, ESD workflows, BOMs, sourcing, test fixtures, and build documentation.
Fleet Service Maintenance Technician
Released full embedded systems design for Wayve, built complex vehicle harness systems, prototype test benches, CAN/LIN diagnostic workflows, SOPs, and helped launch a new R&D service facility.
R&D Engineering Technician - Propulsion and Central Test
Executed electrical and mechanical testing for propulsion and HV systems, improved test readiness with harnesses, fixtures, and validation tools.
R&D / AV Technical Operations
Supported autonomous vehicle integration, diagnostics, retrofits, sensor and compute systems, field readiness, and fast feedback loops to engineering teams.
Where It Started
Before autonomous vehicles and robotics, these roles built the habits I still bring to every prototype: precision, reliability, practical troubleshooting, and ownership in the field.
Photo Department Management / Pharmacy Clerk
Managed photo-department workflows, monitored print quality, supported customers, maintained inventory, and coordinated service issues in a fast-paced environment.
Precision + customer serviceLicensed Courier
Built a strong foundation in safe operation, route planning, time-critical execution, accountability, and dependable field work.
Safety + reliabilitySales and Service Representative
Installed, serviced, diagnosed, and refurbished commercial dishwashing systems across electrical, mechanical, plumbing, and chemical-delivery systems.
Technical field serviceEngineering Without Borders
In 2025, I was selected for the first team to launch Wayve's roadshow momentum in Canada. I helped keep the vehicle, supporting equipment, and software ready for long-distance operation—then carried those lessons to teams across Europe.
Launch Market
Europe Mission
Europe Mission
Europe Mission
I made sure the team had what the vehicle might need over long-distance travel—from spare tires and essential maintenance chemicals to the supporting equipment required in the field.
I supported software updates, confirmed the system stayed current, and remained available to troubleshoot issues that could affect roadshow reliability.
Because Canada was the first launch, I documented observations, identified pain points, and captured lessons that could make future roadshows more repeatable.
I then supported teams in Germany, France, and Switzerland, bringing practical knowledge from the Canadian launch and adapting it to new environments and cross-functional teams.
Mission Gallery
Selected moments from Wayve's 2025 international roadshow, documenting the environments and milestones behind the mission.
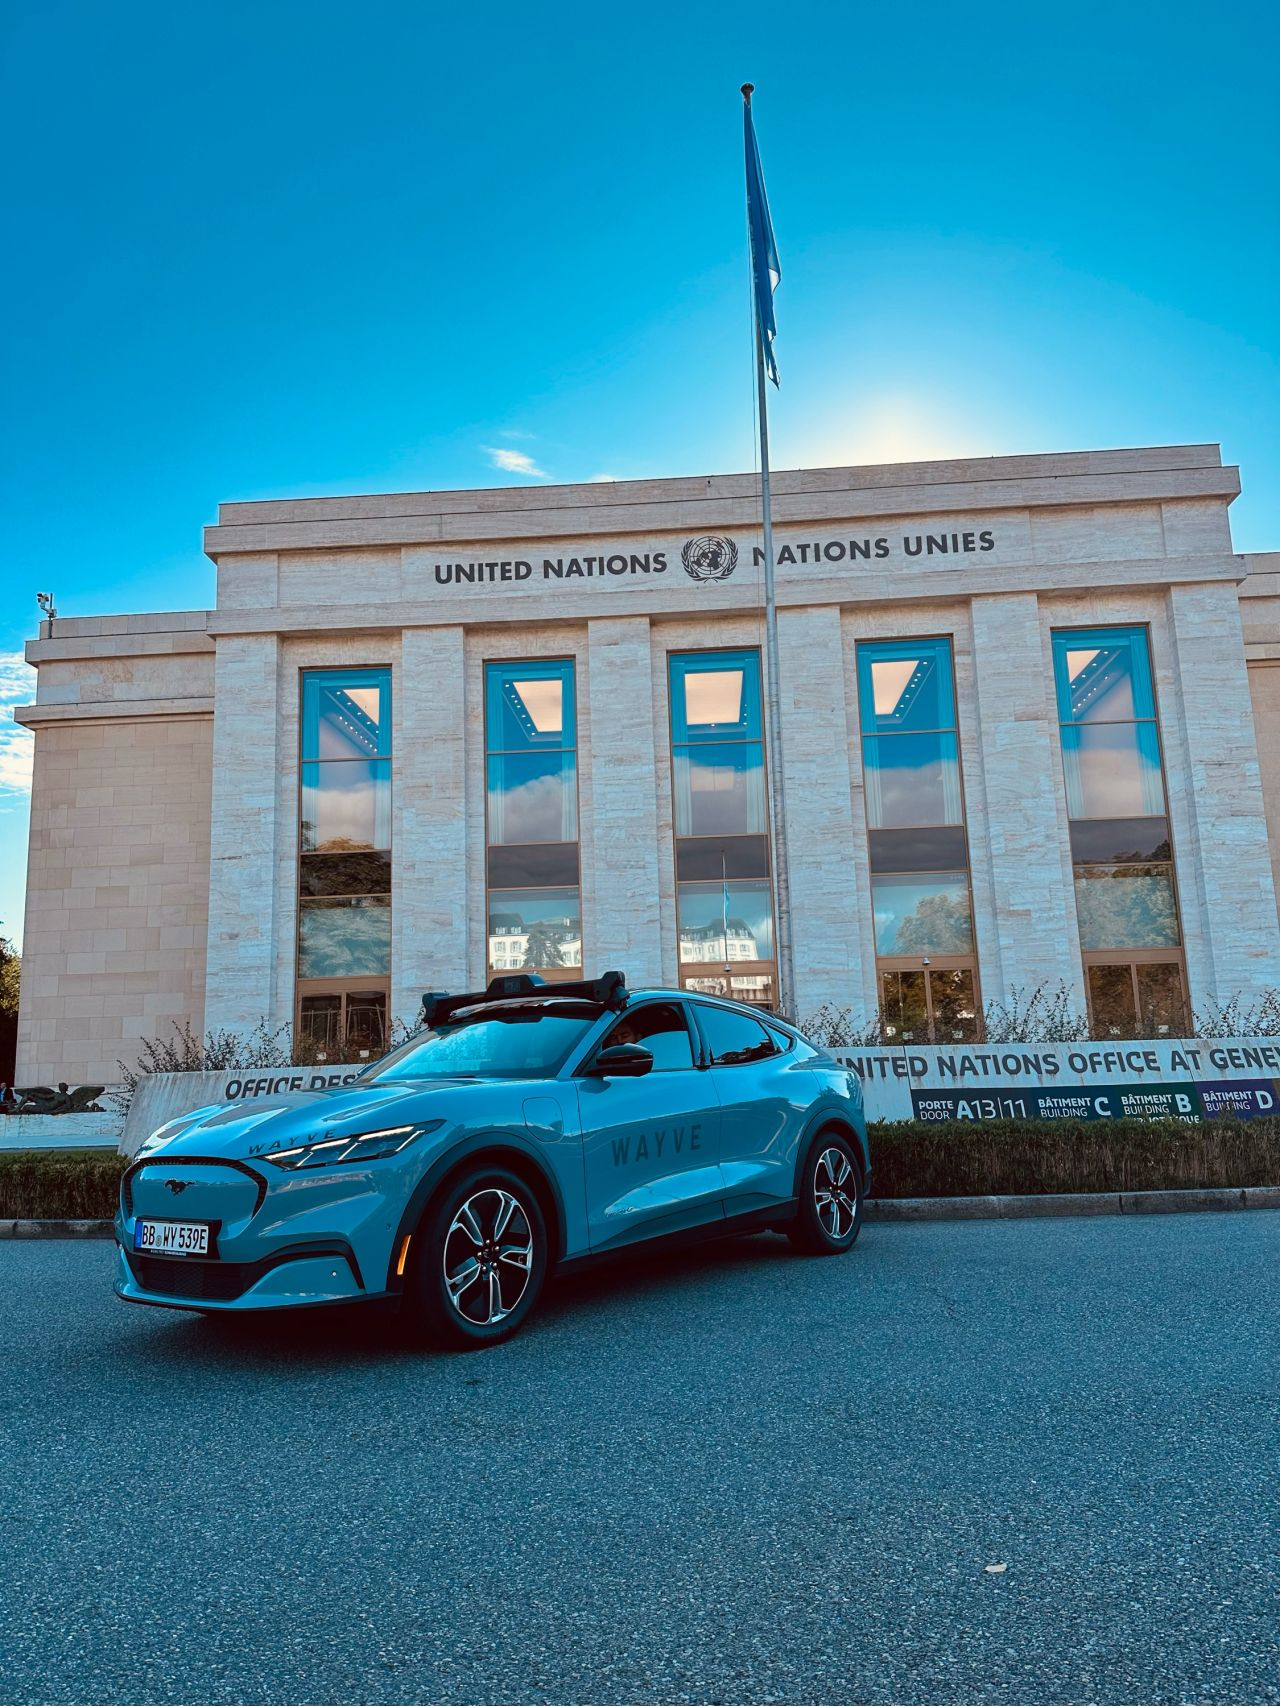
Wayve international roadshow at the United Nations Office at Geneva.
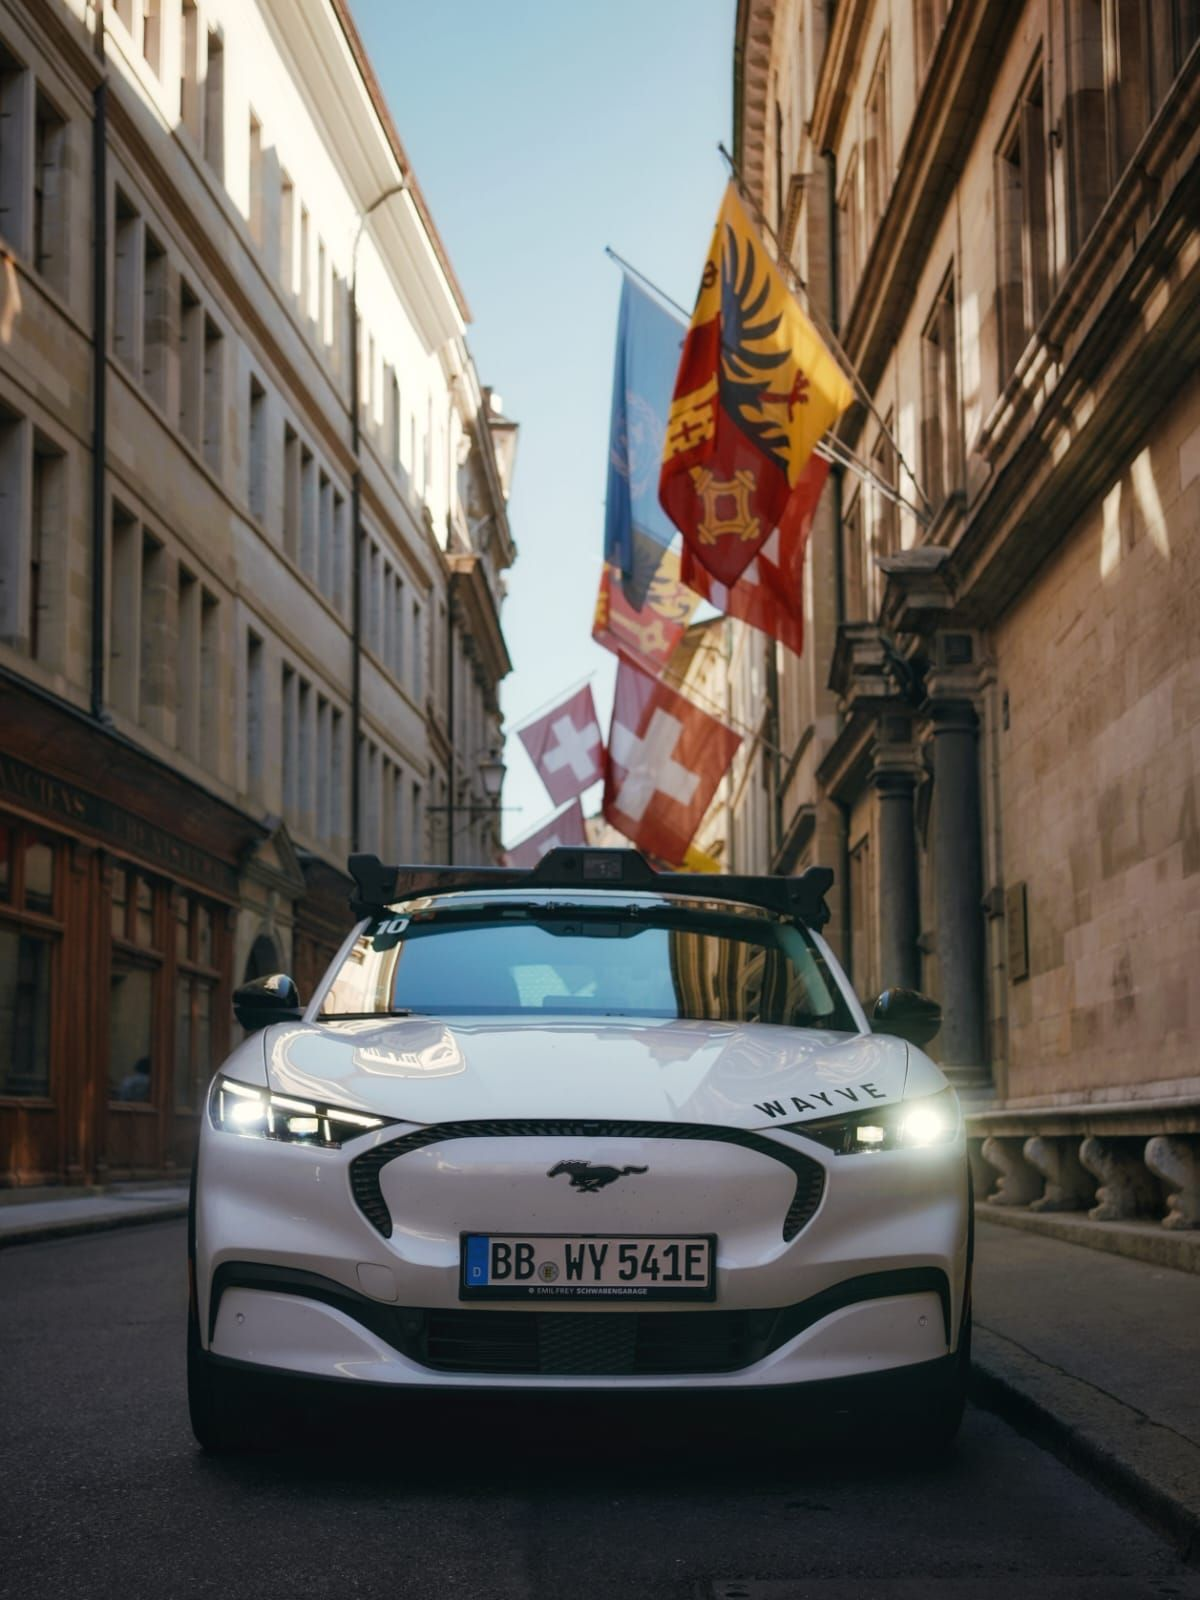
Wayve international roadshow field operations in Switzerland.
Capabilities
Available for
Selected Projects
Arduino-based diagnostic tool with live CAN frame capture, TFT visualization, configurable baud rates, filtering, and bench signal generation for software validation.
Designed and released harnesses using Rapid Harness, with clear separation of power, communications, and safety paths for prototype systems.
Bench hardware for introducing controlled faults into vehicle and subsystem networks during diagnostics and validation work.
Small-system representation of larger high-voltage behavior, built to support repeatable bench testing and engineering checks.
End-of-line booth for functionality checks and final validation support around lidar hardware before release or deployment.
CAD-designed and 3D-printed fixture for IPC457 testing, iterated until the fit and function matched the test need.
Personal embedded-systems build for environmental control and backup power, using a custom battery pack, protection electronics, and control hardware to reduce manual intervention.
Builder Mindset
My portfolio also includes reclaimed-wood furniture, camper van work, a mobile planter, grooming-shop garage conversion support, IR sniffer experiments, and a fully automated monotub with embedded control and backup power. The thread through all of it is the same: make the system real, useful, serviceable, and better after every iteration.
Contact